
Turn abandoned patents
into your own filing
into your own filing
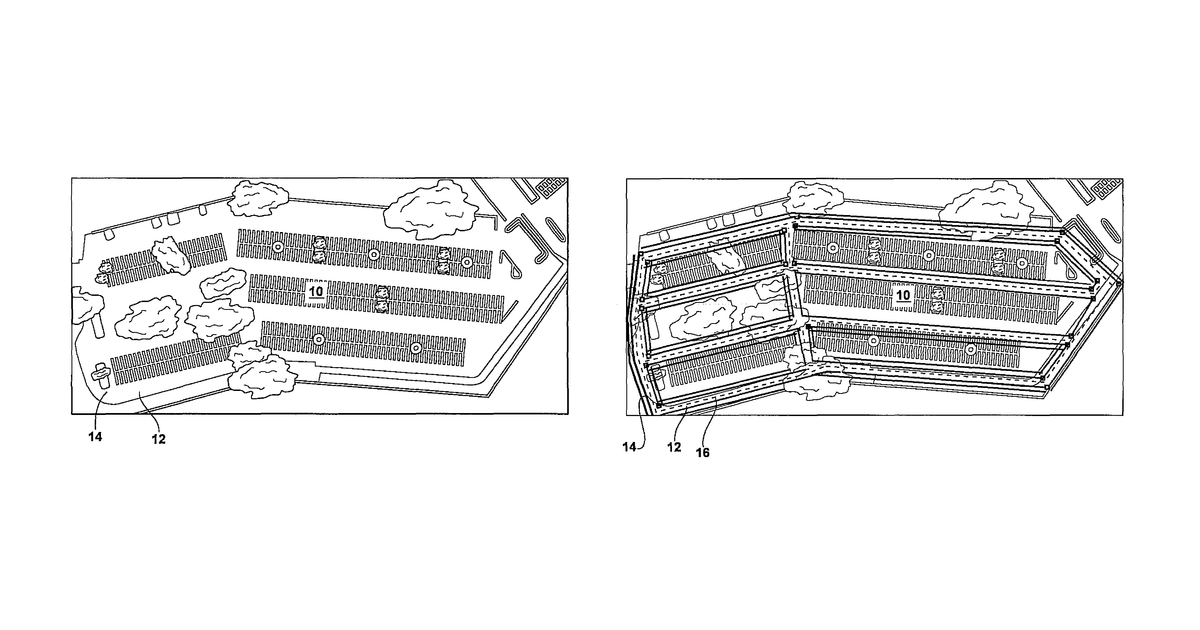
This invention describes a method to identify the main driving directions within an unknown environment, particularly useful for self-driving vehicles. It creates a specialized map, called a Markov random field, where each point represents a location. By analyzing lines and shapes detected in images of the environment, it calculates the most probable driving direction for each location. The claims specifically detail this approach using a Markov random field model.
Why it matters: Filed before the widespread adoption of advanced computer vision and deep learning techniques, which could significantly enhance the accuracy of linear feature detection and the efficiency of probabilistic models like Markov Random Fields. The massive growth in autonomous vehicle development since 2008 also provides a much more mature application landscape.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


