Turn abandoned patents
into your own filing
into your own filing
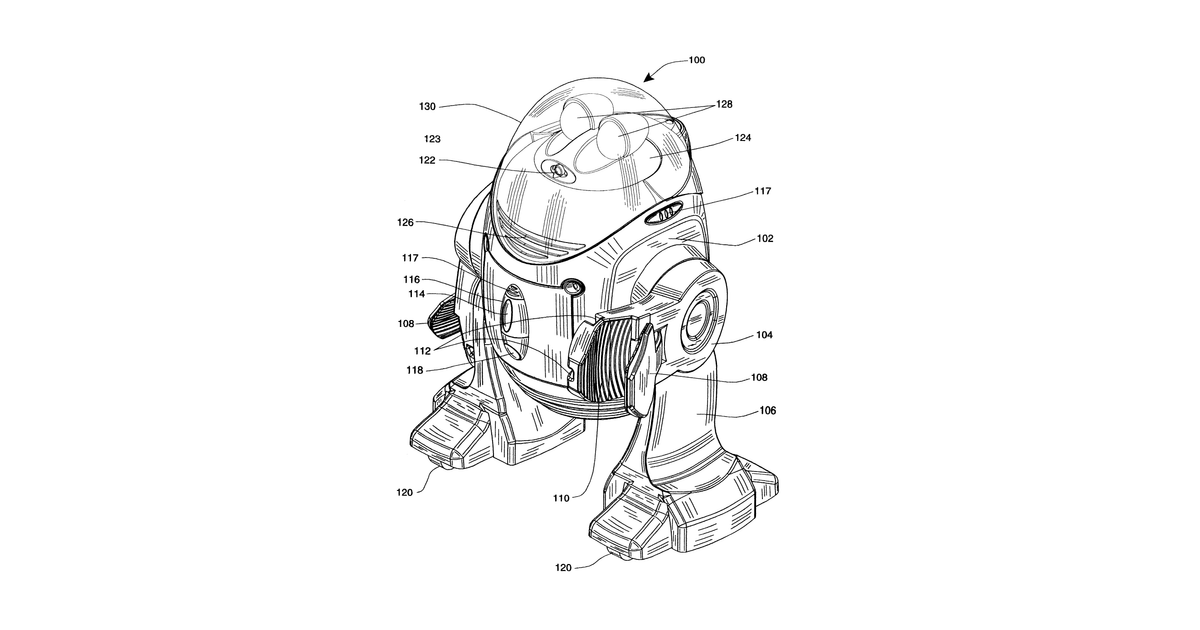
This is a robot designed to pick up objects. Its arm has a unique gripper with one finger fixed to the arm and another finger that moves to grasp things. Inside the arm, a motor turns a screw, which then moves a series of gears. One of these gears has a pin that pushes a lever, causing the movable finger to close. The design specifically details this mechanical gripping mechanism, rather than the broader robot features like sensors or autonomous movement mentioned in the abstract.
Why it matters: Filed before widespread accessible 3D printing and advanced microcontrollers, the custom mechanical gripper parts are now much cheaper to prototype and manufacture. Modern robotics software and AI also make it far easier to integrate such a gripper into a sophisticated, autonomously operating robot, as hinted in the original abstract.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


