Turn abandoned patents
into your own filing
into your own filing
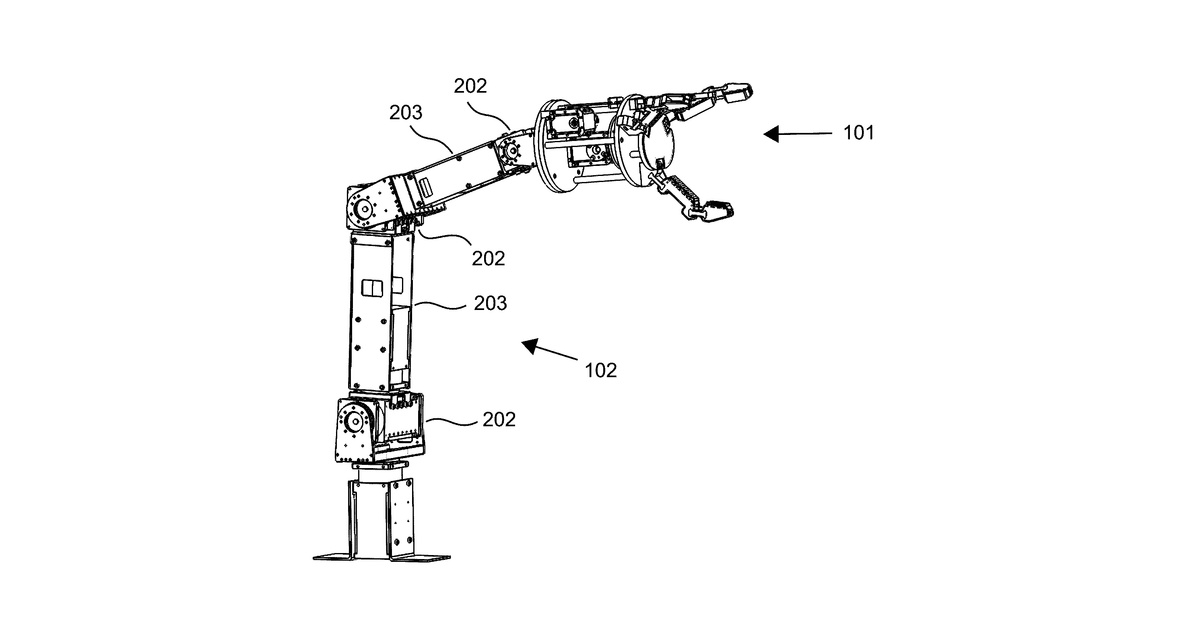
This invention describes a robot system designed to pick produce like apples. It uses a special gripper with multiple fingers that are pulled by cables (tendons) and can move independently. This gripper is designed to be "underactuated," meaning it uses fewer motors than joints, allowing it to adapt its shape to the fruit for a strong, secure grip, similar to how a human hand picks. The robot arm then uses a "look-and-move" strategy, likely involving cameras, to find the fruit and position the gripper.
Why it matters: Since 2016, significant advancements in computer vision and machine learning have made "look-and-move" strategies for object detection and grasping much more reliable and precise, directly addressing a core challenge for robotic harvesting. This could simplify the perception and planning required for the system's manipulator.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


