
Turn abandoned patents
into your own filing
into your own filing
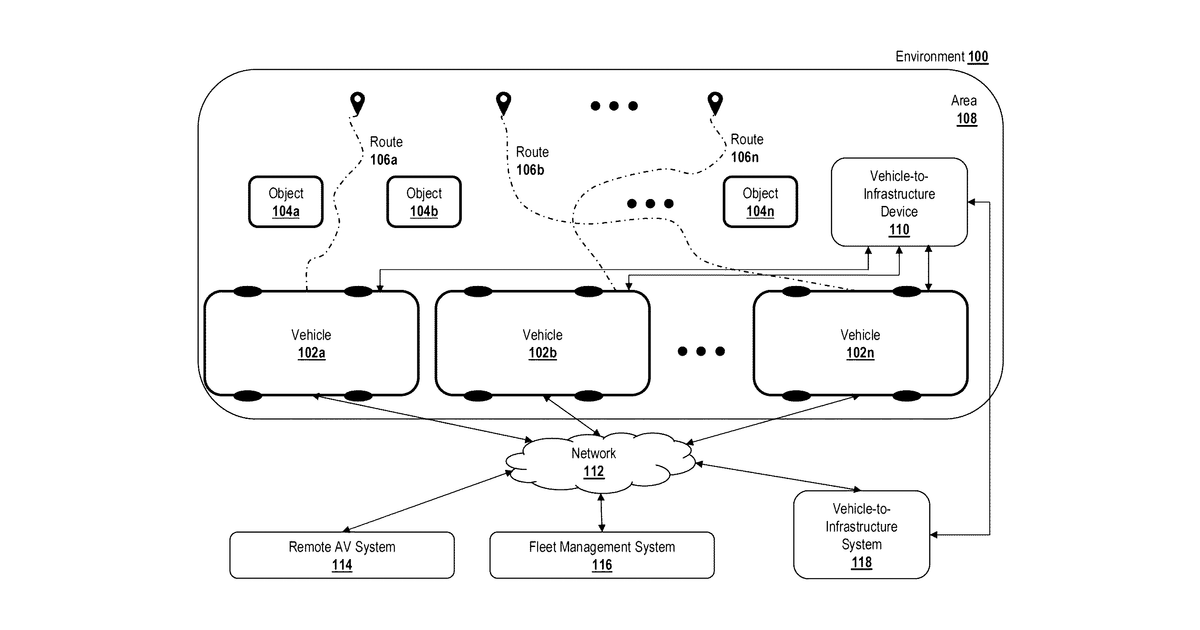
This invention describes a system for self-driving vehicles to navigate around obstacles. It works by first sensing the vehicle's surroundings to create a map of obstacles. Then, it plans a general route to the destination and, based on that route and the vehicle's intended direction, calculates a more precise, short-term path to a nearby point on the general route, which the vehicle then follows. The claims specify transforming vehicle location and the reference path into the map's coordinate system for this calculation.
Why it matters: Real-time path optimization remains computationally demanding for autonomous vehicles. While processing power has increased since 2022, this specific algorithmic approach may still be too complex or have been superseded by more efficient methods.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


