
Turn abandoned patents
into your own filing
into your own filing
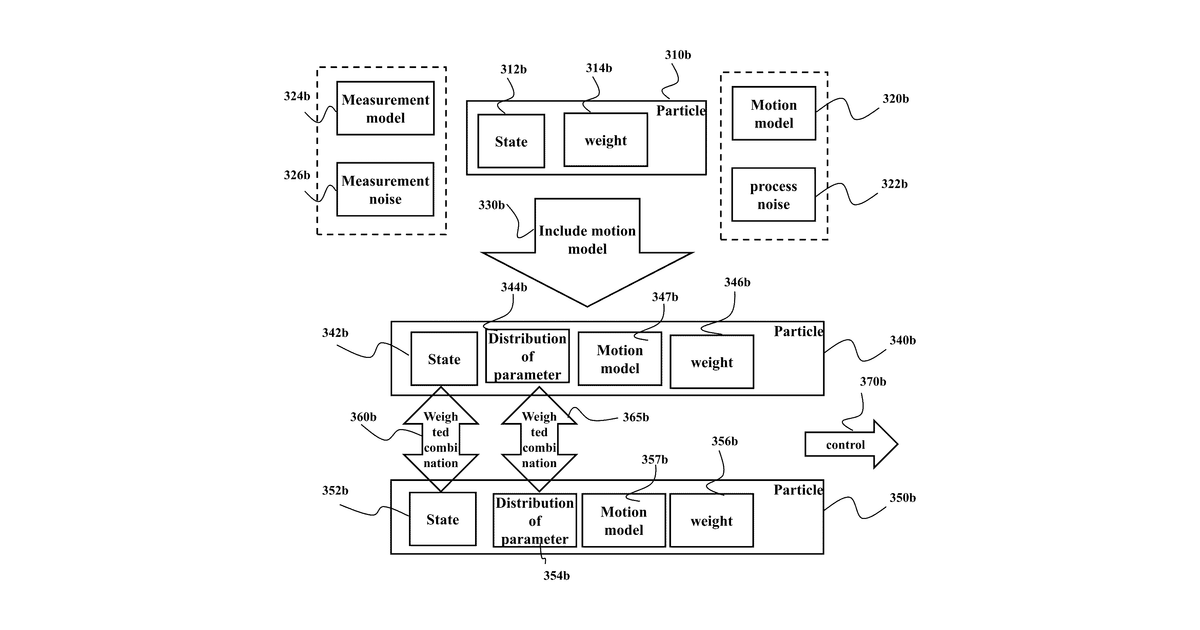
This invention describes a smart controller for robots that uses a probabilistic filter to understand the robot's current situation. It constantly learns and updates how uncertain its own understanding is, specifically by adjusting a complex mathematical model of uncertainty based on new data. This allows the robot to adapt its behavior while always respecting its physical limitations or operational rules.
Why it matters: Since 2022, advancements in probabilistic machine learning frameworks and increased computational power have made real-time learning and updating of complex uncertainty models, like time-varying Gaussian processes, more practical for adaptive robotic control.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


