
Turn abandoned patents
into your own filing
into your own filing
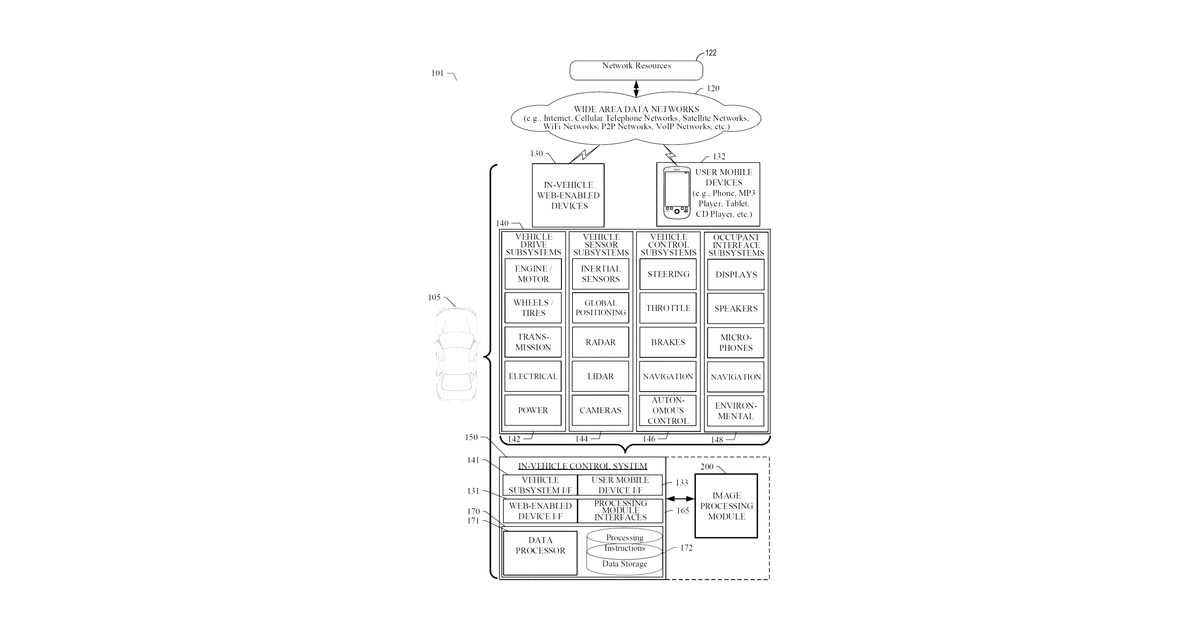
Autonomous vehicles rely on accurate maps to navigate. This invention describes a system where a self-driving car continuously compares what its sensors detect in the real world with its stored navigation map. If it finds any inconsistencies, like a new road layout or obstacle, it then triggers a more detailed mapping process to update its internal map. The vehicle then uses this newly updated map to continue driving, using a less resource-intensive method to spot initial differences before engaging the full mapping system.
Why it matters: Machine learning models for real-time perception and mapping have become significantly more efficient since 2023, making the computationally intensive mapping step more feasible for on-board autonomous vehicle systems.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


