
Turn abandoned patents
into your own filing
into your own filing
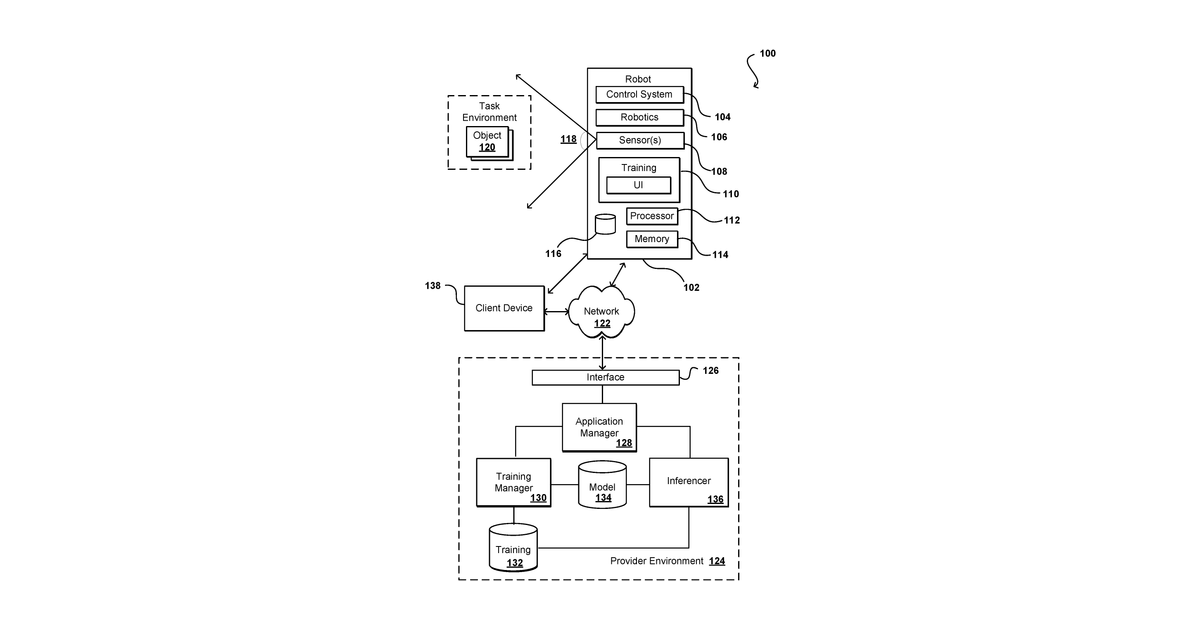
A robot can learn new tasks by observing a human demonstration through image data. It uses artificial intelligence models to first understand how objects interact during the task, then to generate a step-by-step plan based on those interactions. After the plan is confirmed, another AI model translates it into instructions for the robot to perform the task. The claims specify that the initial understanding of object interactions comes from analyzing image data.
Why it matters: Since 2019, the capabilities of large language models and foundation models have dramatically improved, making the inference of complex relationships from visual data and the generation of detailed, actionable plans significantly more robust and accessible. Advances in GPU hardware and robotics simulation also make training and deploying such systems more feasible.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


