
Turn abandoned patents
into your own filing
into your own filing
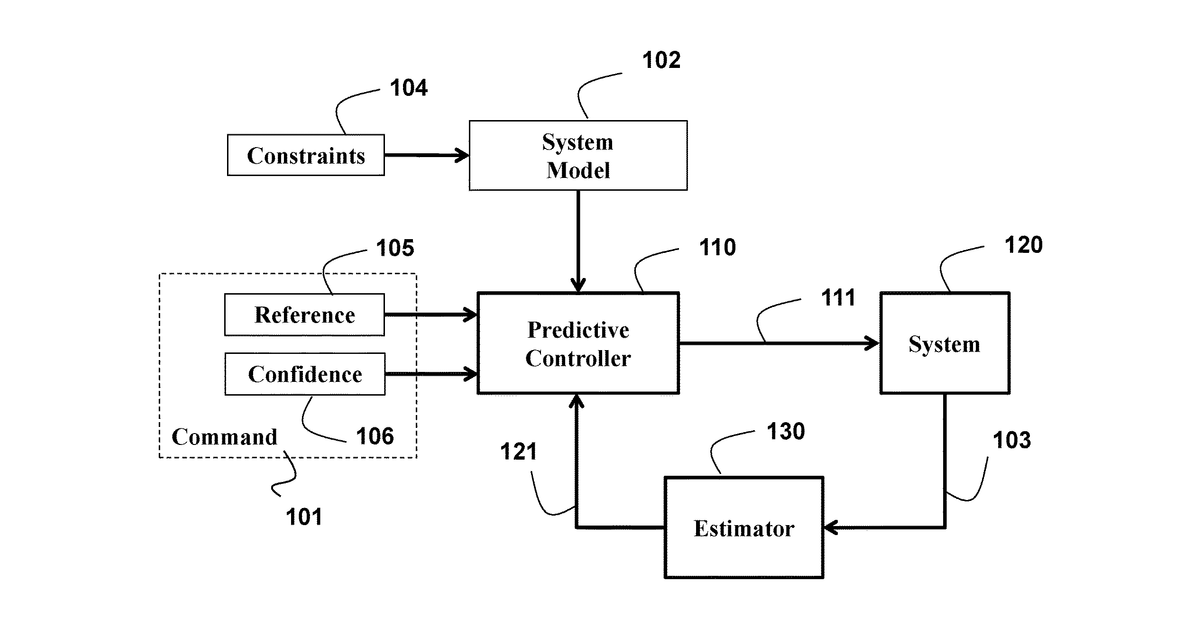
This invention describes a system for controlling self-driving or partially self-driving vehicles. It uses a planning component that figures out possible future paths for the vehicle, along with how likely each path is. A separate control component then steers the vehicle, adjusting its movements based on this plan. If the planning component is very confident about a specific part of the path, the control system prioritizes sticking very closely to that part.
Why it matters: The computational demands for real-time probabilistic planning and adaptive control have become more feasible with advancements in vehicle-grade AI processors and sophisticated simulation environments since 2020.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


