
Turn abandoned patents
into your own filing
into your own filing
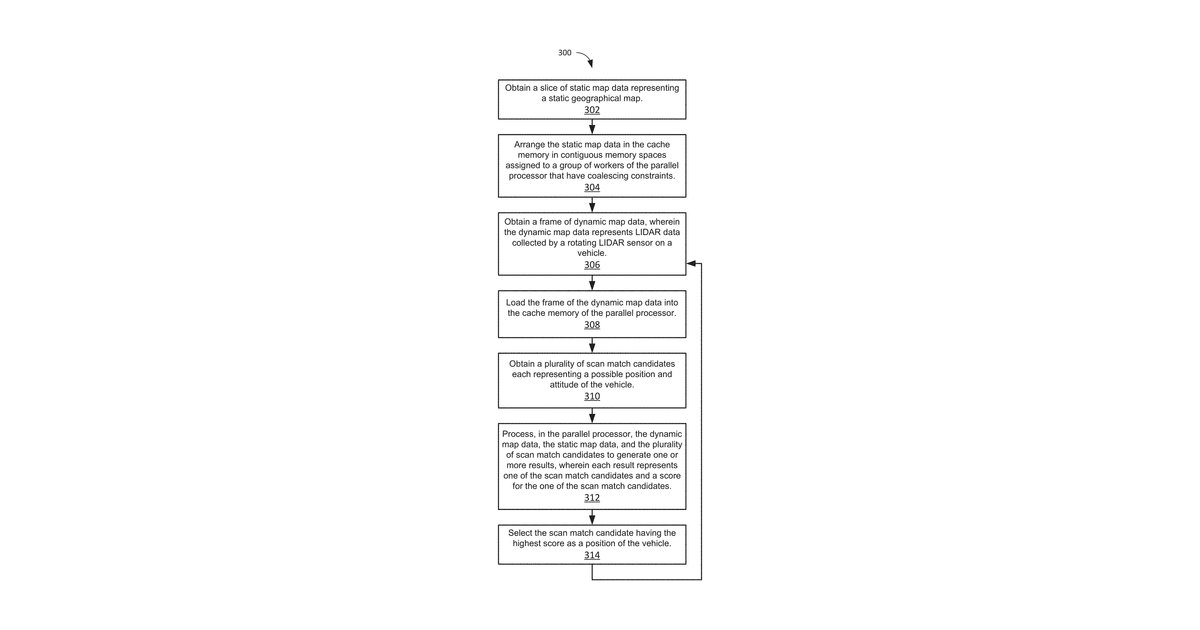
This invention helps self-driving vehicles pinpoint their exact location by comparing what they sense in real-time with a pre-existing map. It achieves this by efficiently processing large amounts of map data using a parallel computer, specifically by organizing the static map data in a special 'three-dimensional rounding buffer' within the computer's memory to quickly find the best match for the vehicle's position and orientation.
Why it matters: Filed when specialized parallel processing for autonomous vehicles was still maturing. Advances in GPU hardware and software frameworks, particularly for optimizing memory access patterns and handling large 3D datasets, could make implementing this specific approach more practical and performant today.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


