
Turn abandoned patents
into your own filing
into your own filing
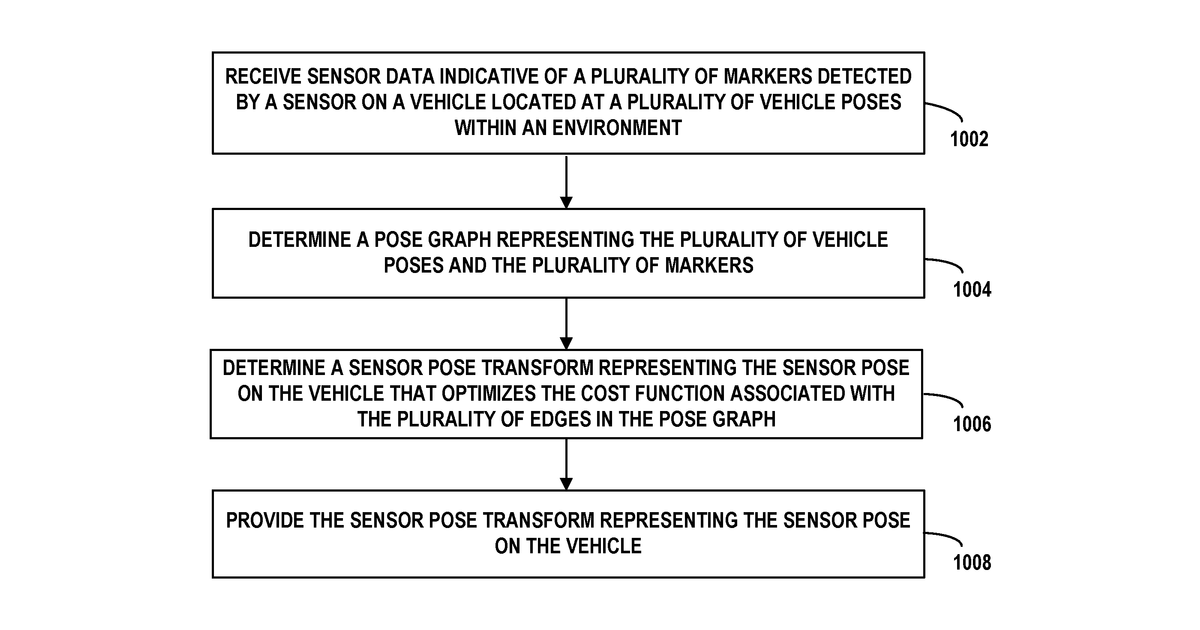
This invention helps a robot precisely determine its location and how its sensors are mounted, or even fine-tune its internal movement parameters. It works by having the robot observe specific markers in its environment, then building a detailed map of its journey and the markers. The system then uses this map to mathematically adjust all measurements, creating the most accurate possible understanding of its position and internal settings, specifically for wheeled robots, including factors like wheel diameter and turning delays.
Why it matters: Since 2020, the proliferation of affordable, powerful sensors and edge computing for mobile robots has made complex graph-based localization and calibration systems more practical and accessible for a wider range of robotic applications.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


