
Turn abandoned patents
into your own filing
into your own filing
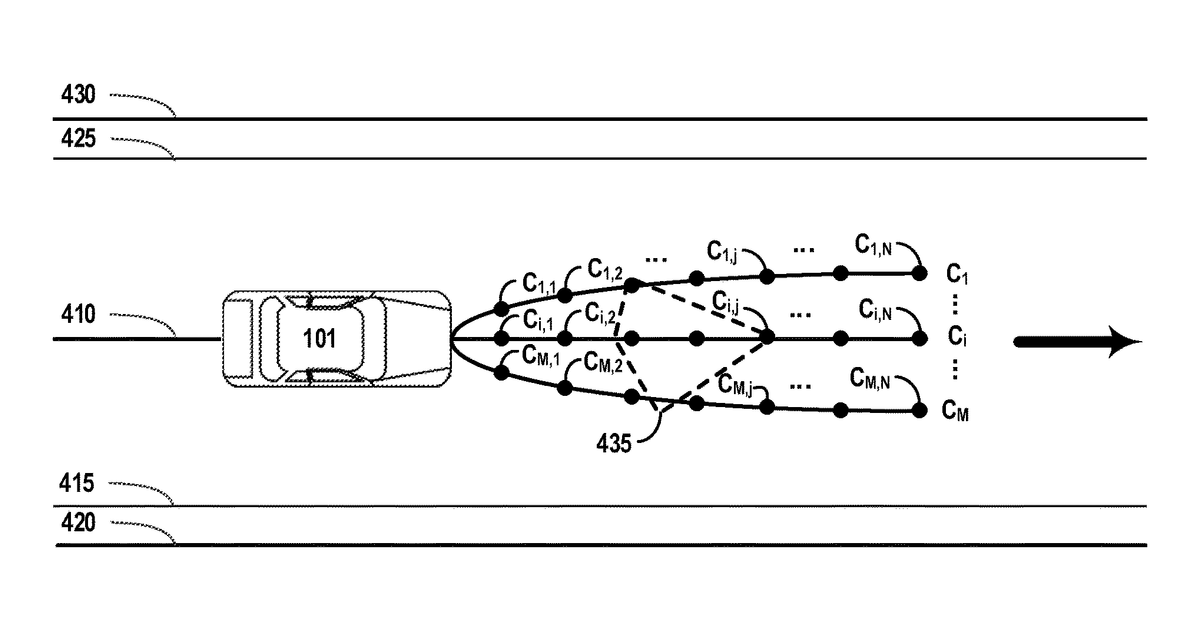
This invention describes a computer program for self-driving cars to choose the best path when encountering an obstacle in a lane. It works by creating several possible paths, then evaluating each path point by point based on different characteristics like avoiding obstacles (high priority) or staying within lane boundaries (lower priority). The program calculates a total "cost" for each path by combining these evaluations and then selects the path with the lowest cost.
Why it matters: Filed before the significant advancements in AI and machine learning for real-time autonomous driving path planning. Modern AI techniques could now more efficiently learn and execute the complex attribute evaluation and prioritized cost aggregation described.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


