
Turn abandoned patents
into your own filing
into your own filing
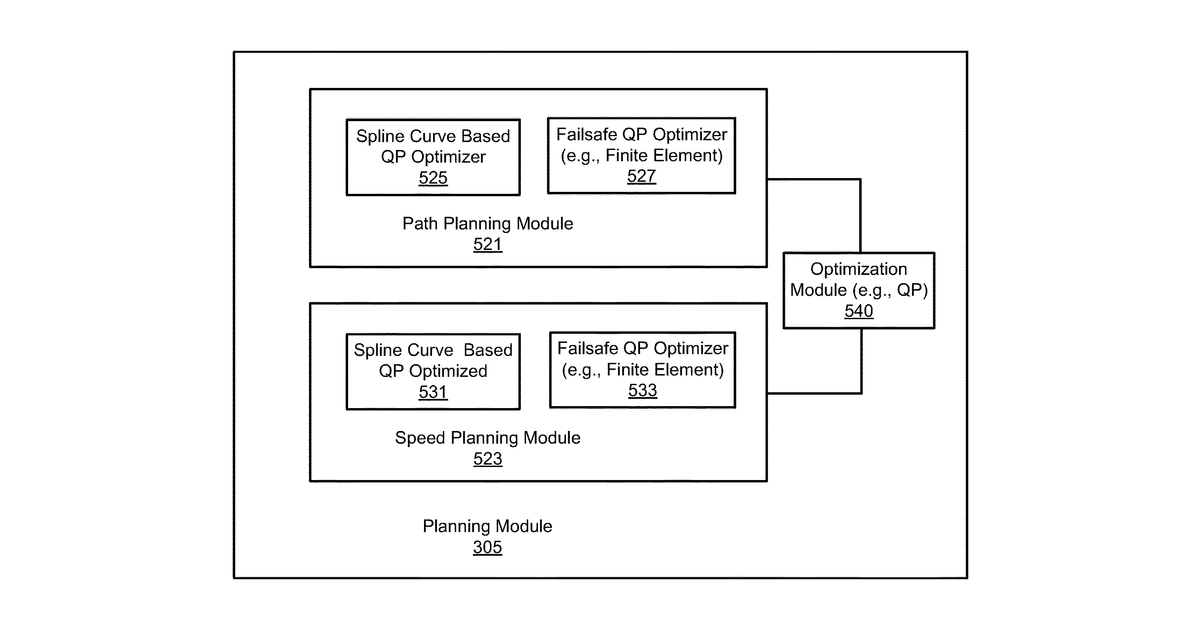
This invention describes a computer program for self-driving cars that figures out the best way to drive. It first plans a general route, then fine-tunes it by considering traffic rules and obstacles. The core idea is a two-step path correction: it tries a quick, smooth curve adjustment first, and if that fails to meet safety standards, it switches to a more detailed, complex calculation. Finally, it adjusts the car's speed along this optimized path, specifically considering the car's current speed, speed limits, and how sharp turns are.
Why it matters: Autonomous vehicle technology has matured significantly since 2018, making robust, real-time fallback path planning more feasible and critical. Advances in AI and computational power now better support the complex, real-time calculations required for this two-tiered optimization approach.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


