
Turn abandoned patents
into your own filing
into your own filing
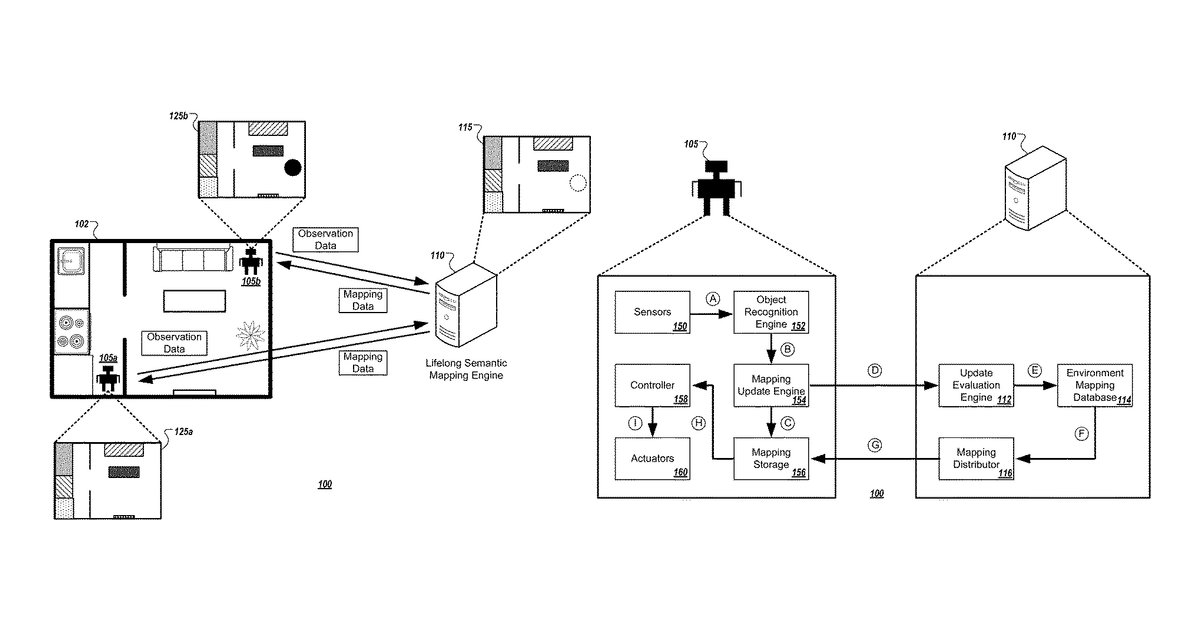
This invention describes a system for robots to find lost items. It works by keeping a map of the robot's environment that tracks where different objects are likely to be, and how those probabilities change over time since the object was last seen. When asked to find something, the system uses this map to figure out the most probable location and then guides the robot there.
Why it matters: Filed before widespread adoption of advanced computer vision and foundation models, which now make robust semantic understanding of environments and objects significantly more feasible and accurate. This directly enhances the system's ability to build and maintain the detailed semantic maps it relies on.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


