
Turn abandoned patents
into your own filing
into your own filing
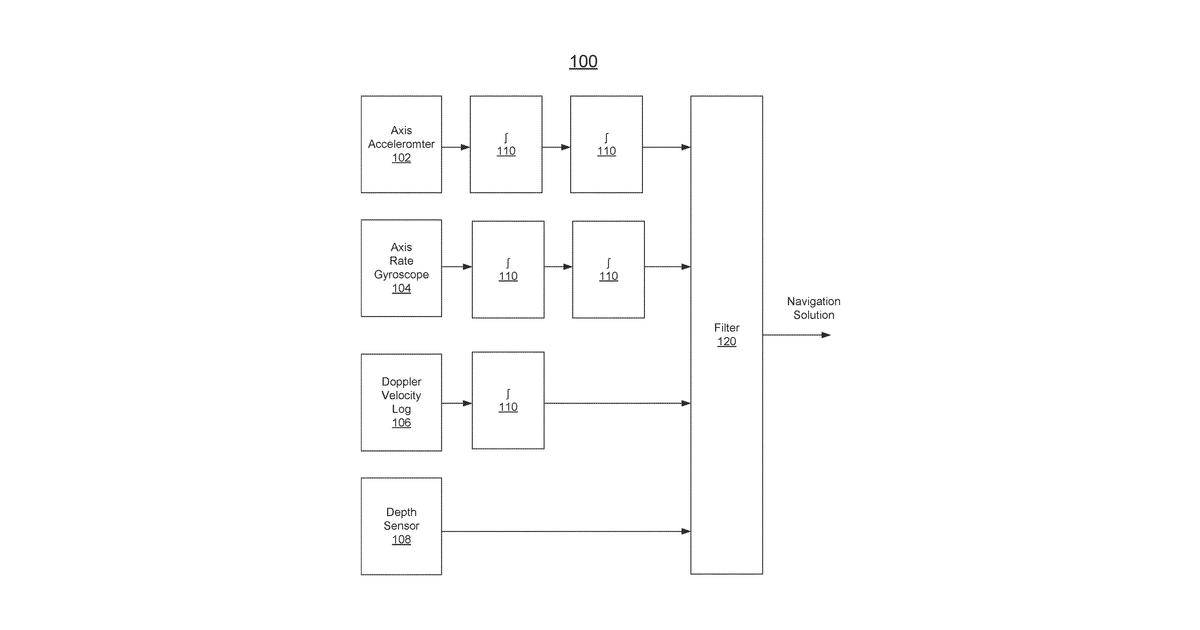
This invention describes a way for an autonomous underwater vehicle (AUV) to navigate by retracing its exact path. It first maps the seabed in detail as it travels in one direction. Then, on its return journey, it continuously takes new, smaller seabed images and compares them to the original map to precisely determine its position and adjust its course to stay on the identical route, using a numerical match score to guide the vehicle.
Why it matters: The significant advancements in embedded processing and computational power since 2016 make real-time synthetic aperture sonar imaging and complex correlation on an AUV more practical and power-efficient. This enables more robust and precise underwater navigation than previously possible.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


