
Turn abandoned patents
into your own filing
into your own filing
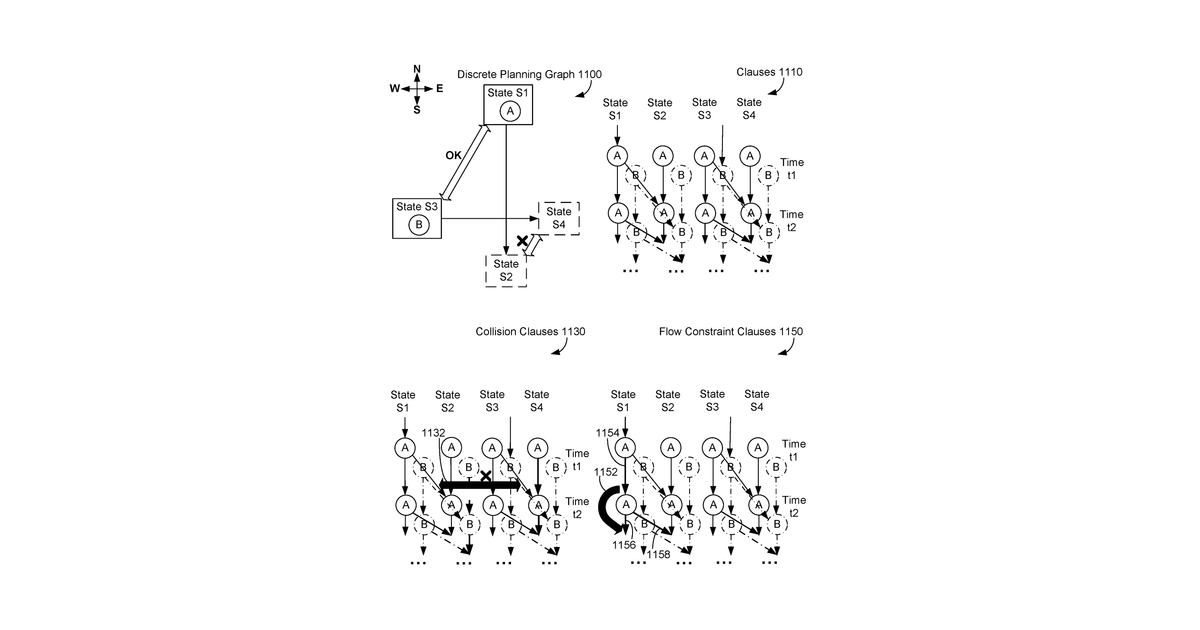
This invention describes a way for a computer to plan routes for robots. It takes a map of possible paths, breaks it into small, uniformly-sized segments, and then uses a special mathematical logic puzzle (a Boolean equation) to find the best sequence of segments for the robot to follow.
Why it matters: Since 2016, advancements in SAT solver efficiency and the proliferation of complex autonomous robots have increased the demand for robust, verifiable path planning solutions like this.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


