
Turn abandoned patents
into your own filing
into your own filing
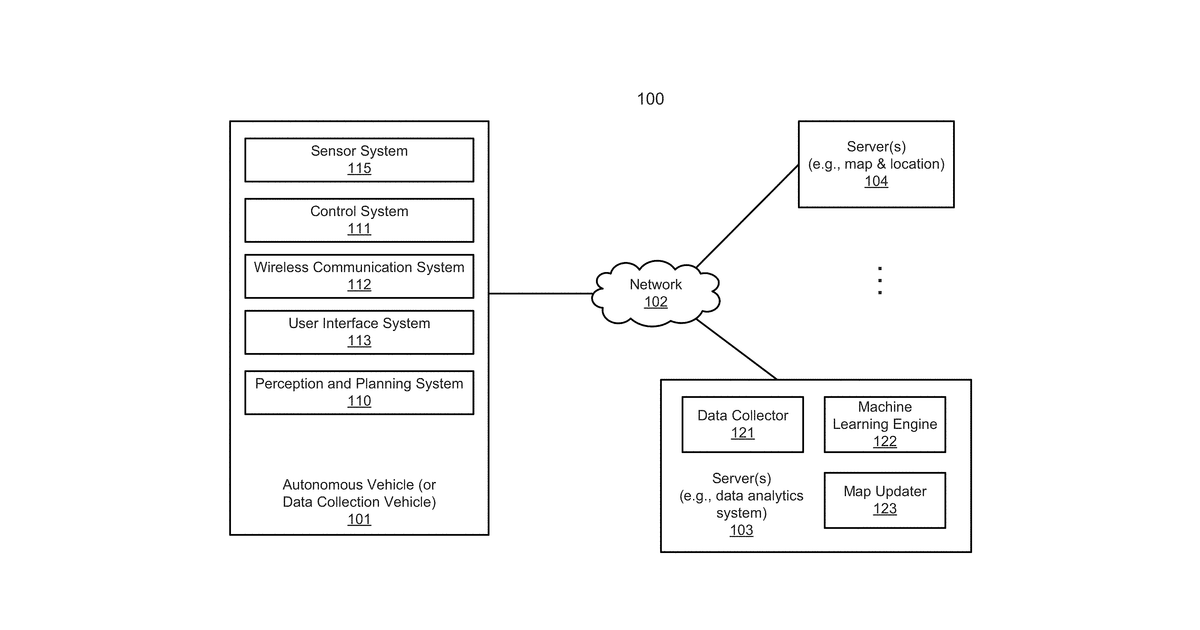
This describes a system where a self-driving car continuously updates its own navigation maps. The car collects its current location data and compares it against its existing map to find potential matching positions. It then calculates a confidence score for these potential matches, and if the score is high enough, it uses the best match to update the map, making it more accurate for future navigation.
Why it matters: Filed when real-time processing of diverse sensor data for map updates was computationally intensive. Today, advancements in vehicle computing and sensor fusion make self-updating localization maps more practical and accurate.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


