
Turn abandoned patents
into your own filing
into your own filing
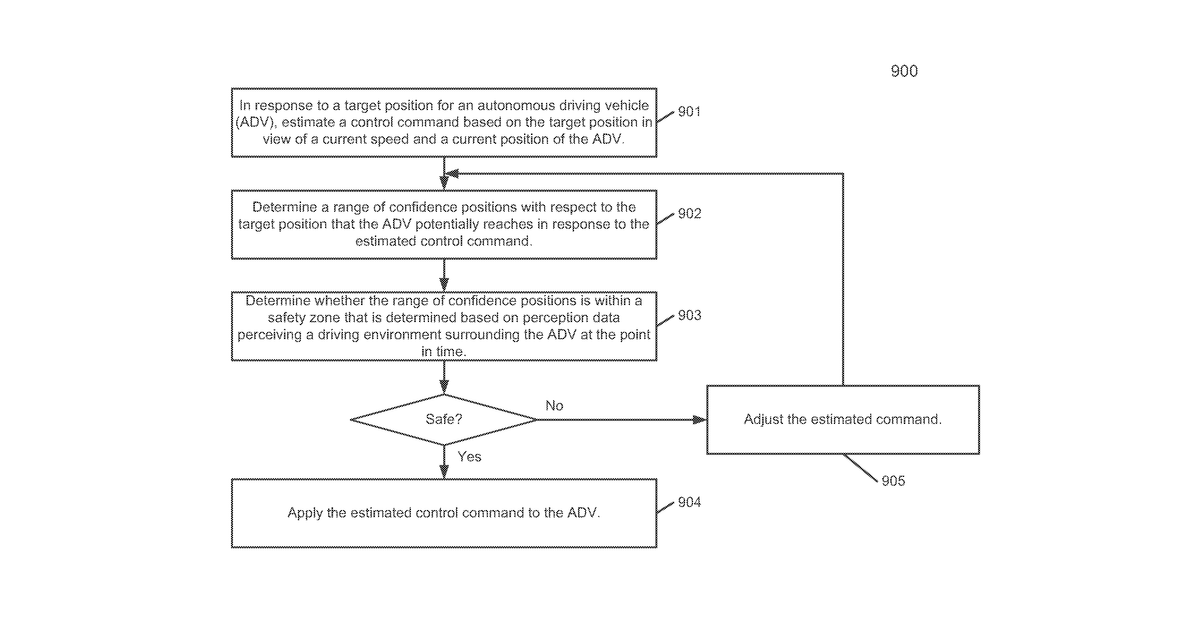
This invention describes a method for an autonomous vehicle to plan its movements safely. It works by first suggesting a driving command to reach a target, then predicting all the places the vehicle might end up if it executes that command. It checks if these potential positions are within a safe area, defined by what the vehicle's sensors see around it. If it's safe, the command is used; otherwise, the vehicle tries a different command until a safe one is found, potentially up to a set number of attempts.
Why it matters: Filed before significant advancements in AI/ML for perception and prediction. Modern computational power and sensor fusion techniques make the iterative safety checks more robust and efficient than in 2017.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


