
Turn abandoned patents
into your own filing
into your own filing
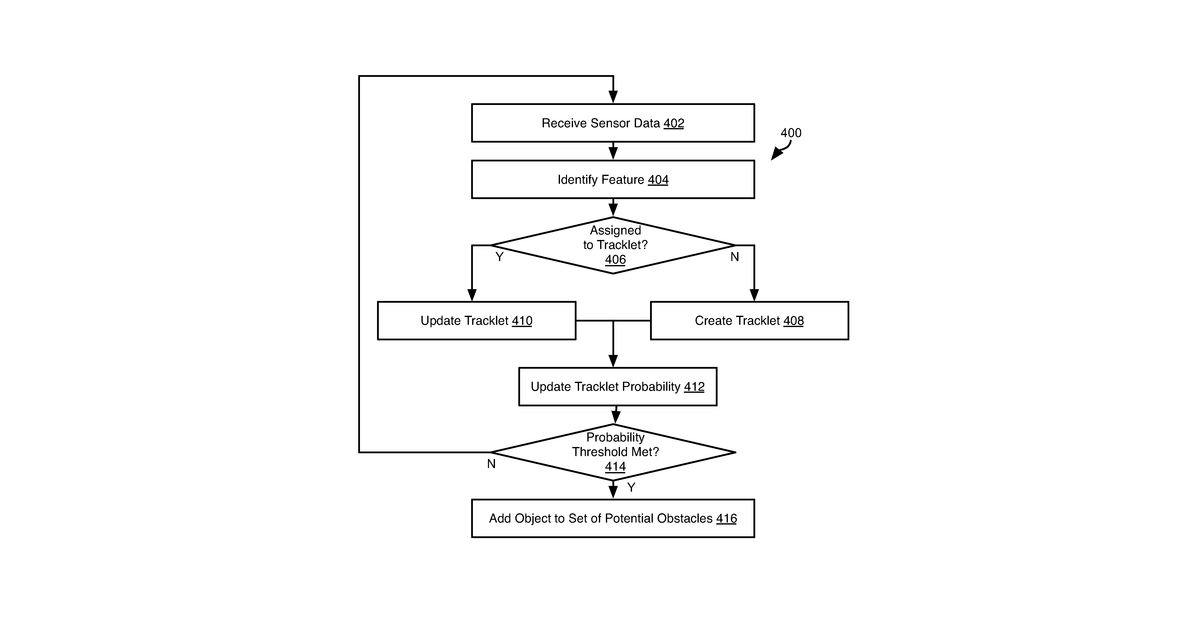
This invention describes a system for a vehicle to detect and track objects around it. It uses data from various sensors like cameras, LIDAR, RADAR, and ultrasound. When an object is first seen, the system starts a record for it, called a tracklet. As the vehicle moves, any new sensor data related to that object is added to its tracklet. The system then calculates the object's likely path using a method called Kalman filtering and continuously updates how certain it is that the object is truly there. If the certainty reaches a high enough level, the vehicle either warns the driver or automatically takes action to avoid the object. The claims specifically narrow this to a vehicle controller using Kalman filtering.
Why it matters: Filed before widespread availability of affordable, high-performance automotive sensors and edge computing hardware. Today, the necessary sensor integration and real-time processing are more feasible and cost-effective.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


