
Turn abandoned patents
into your own filing
into your own filing
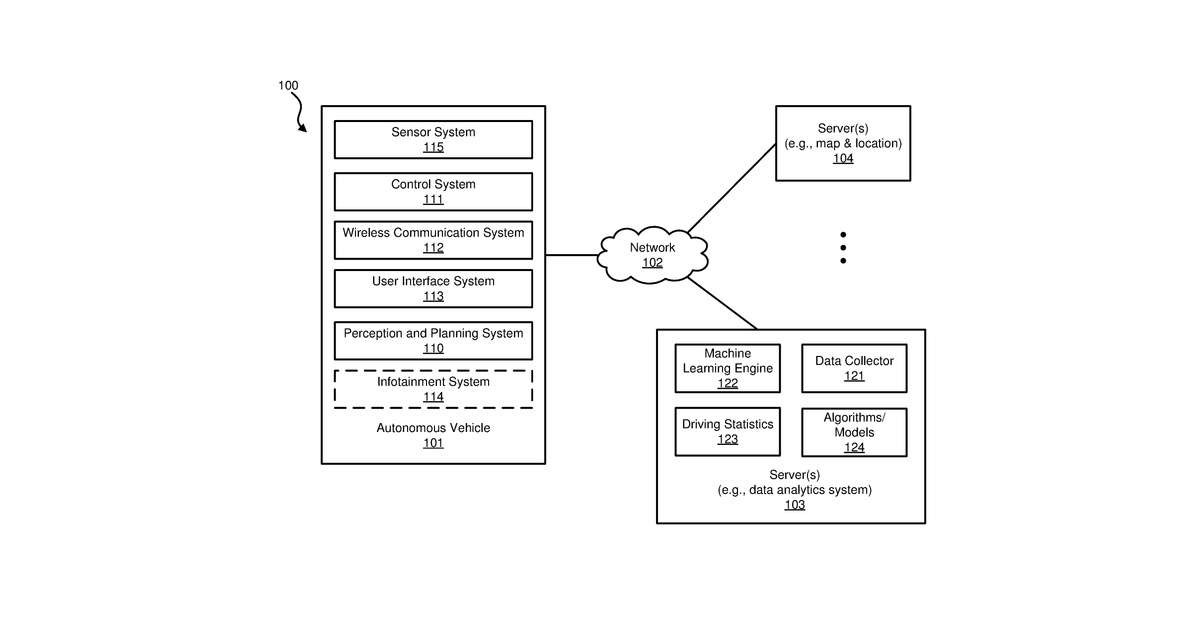
This invention outlines a computer-based method for an autonomous vehicle to safely change lanes. It uses a digital map of the road to identify the earliest and latest points in the current lane where a lane change is feasible, defining a safe window for the maneuver. The system specifically uses a minimum cost algorithm to select the optimal starting point for the lane change.
Why it matters: Filed in 2016, this invention predates the widespread adoption and maturity of advanced machine learning techniques for real-time path planning and decision-making in autonomous vehicles. The 'minimum cost algorithm' and 'topological map' concepts are now significantly more robust and efficient to implement due to advancements in AI, sensor fusion, and computational power in the last decade.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


