Turn abandoned patents
into your own filing
into your own filing
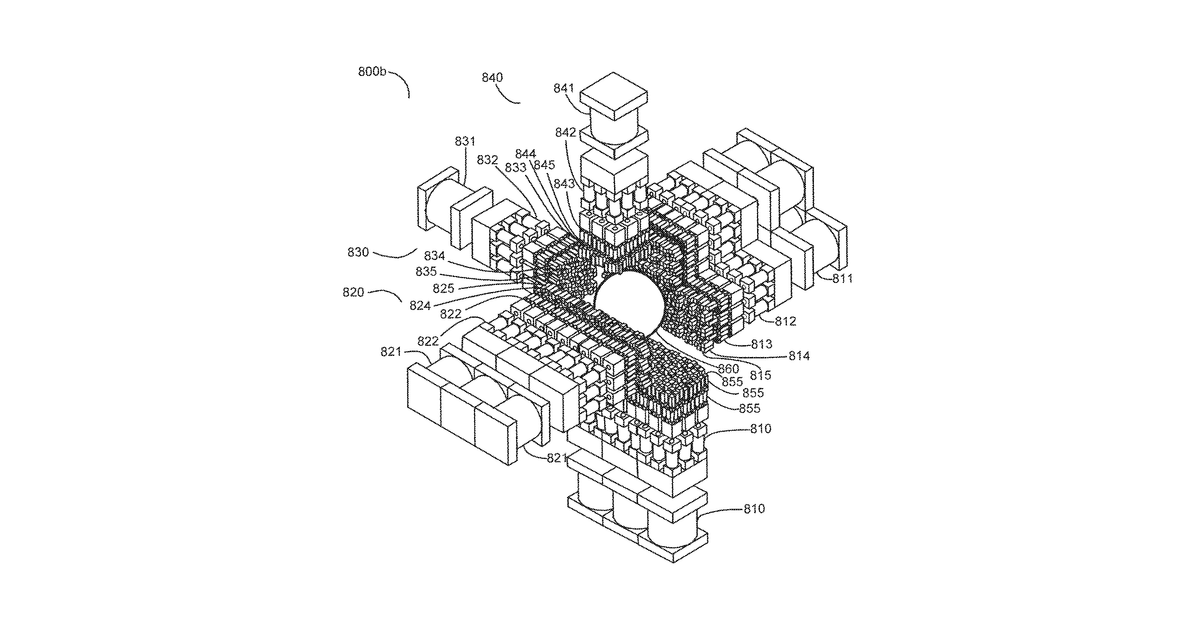
This invention describes a robotic hand that can feel the shape of objects it touches. It uses special internal sensors, some measuring how much parts of the hand move and others measuring linear displacement, to create a detailed map of an object's surface. A computer then uses these measurements to figure out what the object is or its volume, and how to best pick it up. The claims specifically describe a system with both displacement measuring cells and linear displacement sensors working together to measure contours or volume.
Why it matters: Filed before significant advancements in AI/ML for tactile data processing and robotic manipulation, which could now make the object identification and manipulation planning more robust and effective.
AI gives you a few directions you could take this. Pick one, and we check whether your version is different enough to patent, then write the filing.
Reinvent this with AI


